载入中...
搜索中...
未找到
roboctrl::device::gkd_sentry_chassis类 参考final
详细描述
在文件 gkd_sentry_chassis.hpp 第 13 行定义.
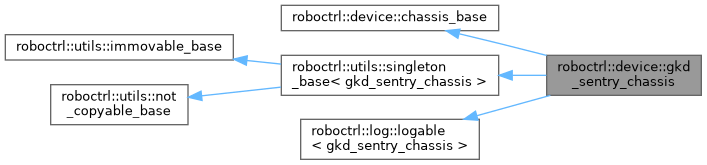
类 roboctrl::device::gkd_sentry_chassis 继承关系图:
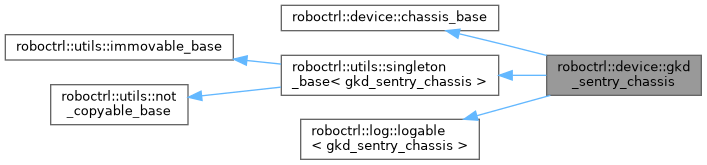
roboctrl::device::gkd_sentry_chassis 的协作图:
Public 类型 | |
| using | base_type = chassis_base |
| using | info_type = chassis_base::info_type |
Public 成员函数 | |
| std::string | desc () const |
| awaitable< void > | task () |
| void | set_planar_velocity (vectorf v) override |
设置平面速度 (x, y),单位由具体底盘约定为 m/s。 | |
| void | set_planar_x (fp32 value) override |
| 单独设置平面 x 方向速度。 | |
| void | set_planar_y (fp32 value) override |
| 单独设置平面 y 方向速度。 | |
| vectorf | velocity () const override |
| 获取当前平面速度目标。 | |
| void | set_rotate_speed (fp32 v) override |
| 设置绕 z 轴的旋转速度。 | |
| fp32 | rotate_speed () const override |
| 获取当前绕 z 轴的旋转速度目标。 | |
| void | set_enabled (bool enabled) override |
| 启用或禁用底盘输出。 | |
| std::array< motor_base *, 4 > | wheel_motors () const override |
| bool | init (const info_type &) |
 Public 成员函数 继承自 roboctrl::device::chassis_base | |
| virtual void | set_velocity (vectorf velocity) |
| 设置平面速度,兼容旧调用点。 | |
| virtual void | set_velocity (fp32 x, fp32 y, fp32 z) |
| 同时设置平移和旋转速度。 | |
| Public 成员函数 继承自 roboctrl::utils::singleton_base< gkd_sentry_chassis > | |
| singleton_base (const singleton_base &)=delete | |
| singleton_base & | operator= (const singleton_base &)=delete |
| Public 成员函数 继承自 roboctrl::utils::immovable_base | |
| immovable_base (immovable_base &&)=delete | |
| immovable_base & | operator= (immovable_base &&)=delete |
| Public 成员函数 继承自 roboctrl::utils::not_copyable_base | |
| not_copyable_base (const not_copyable_base &)=delete | |
| not_copyable_base & | operator= (const not_copyable_base &)=delete |
额外继承的成员函数 | |
| 静态 Public 成员函数 继承自 roboctrl::utils::singleton_base< gkd_sentry_chassis > | |
| static gkd_sentry_chassis & | instance () |
| 获取单例实例 | |
| Protected 成员函数 继承自 roboctrl::log::logable< gkd_sentry_chassis > | |
| void | log (log_level level, std::format_string< Args... > fmt, Args &&...args) const |
| 输出日志 | |
| void | log_debug (std::format_string< Args... > fmt, Args &&...args) const |
| 输出debug日志 | |
| void | log_info (std::format_string< Args... > fmt, Args &&...args) const |
| 输出info日志 | |
| void | log_warn (std::format_string< Args... > fmt, Args &&...args) const |
| 输出warn日志 | |
| void | log_error (std::format_string< Args... > fmt, Args &&...args) const |
| 输出error日志 | |
成员类型定义说明
◆ base_type
在文件 gkd_sentry_chassis.hpp 第 17 行定义.
◆ info_type
在文件 gkd_sentry_chassis.hpp 第 36 行定义.
成员函数说明
◆ desc()
|
inline |
在文件 gkd_sentry_chassis.hpp 第 20 行定义.
◆ init()
| bool gkd_sentry_chassis::init | ( | const info_type & | info | ) |
在文件 gkd_sentry_chassis.cpp 第 22 行定义.
◆ rotate_speed()
|
inlineoverridevirtual |
◆ set_enabled()
|
inlineoverridevirtual |
◆ set_planar_velocity()
|
inlineoverridevirtual |
设置平面速度 (x, y),单位由具体底盘约定为 m/s。
实现了 roboctrl::device::chassis_base.
在文件 gkd_sentry_chassis.hpp 第 23 行定义.
◆ set_planar_x()
|
inlineoverridevirtual |
◆ set_planar_y()
|
inlineoverridevirtual |
◆ set_rotate_speed()
|
inlineoverridevirtual |
◆ task()
| roboctrl::awaitable< void > gkd_sentry_chassis::task | ( | ) |
在文件 gkd_sentry_chassis.cpp 第 14 行定义.
◆ velocity()
|
inlineoverridevirtual |
◆ wheel_motors()
|
inlineoverridevirtual |
Bound actuators in LF, RF, LR, RR order, for control-layer power policy.
重载 roboctrl::device::chassis_base .
在文件 gkd_sentry_chassis.hpp 第 32 行定义.
该类的文档由以下文件生成:
- /home/runner/work/GKD.RoboCtrl/GKD.RoboCtrl/include/device/chassis/gkd_sentry_chassis.hpp
- device/chassis/gkd_sentry_chassis.cpp
