载入中...
搜索中...
未找到
roboctrl::device::referee_protocol::state结构体 参考
详细描述
Source profile: GKD_Control/include/device/referee/protocol.hpp (unversioned). Known commands require their exact source layout; no inferred year upgrades.
#include <state.hpp>
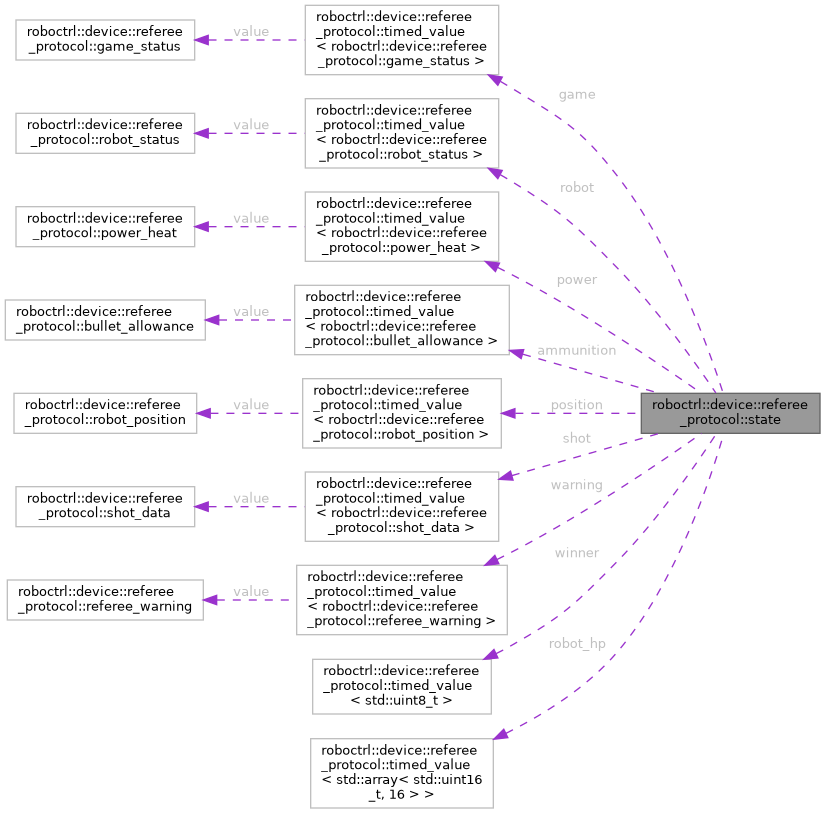
roboctrl::device::referee_protocol::state 的协作图:
Public 成员函数 | |
| bool | accept (const frame &input, clock::time_point now) |
Public 属性 | |
| timed_value< game_status > | game |
| timed_value< robot_status > | robot |
| timed_value< power_heat > | power |
| timed_value< bullet_allowance > | ammunition |
| timed_value< robot_position > | position |
| timed_value< shot_data > | shot |
| timed_value< referee_warning > | warning |
| timed_value< std::uint8_t > | winner |
| timed_value< std::array< std::uint16_t, 16 > > | robot_hp |
成员函数说明
◆ accept()
|
inline |
类成员变量说明
◆ ammunition
| timed_value<bullet_allowance> roboctrl::device::referee_protocol::state::ammunition |
◆ game
| timed_value<game_status> roboctrl::device::referee_protocol::state::game |
◆ position
| timed_value<robot_position> roboctrl::device::referee_protocol::state::position |
◆ power
| timed_value<power_heat> roboctrl::device::referee_protocol::state::power |
◆ robot
| timed_value<robot_status> roboctrl::device::referee_protocol::state::robot |
◆ robot_hp
| timed_value<std::array<std::uint16_t, 16> > roboctrl::device::referee_protocol::state::robot_hp |
◆ shot
| timed_value<shot_data> roboctrl::device::referee_protocol::state::shot |
◆ warning
| timed_value<referee_warning> roboctrl::device::referee_protocol::state::warning |
◆ winner
| timed_value<std::uint8_t> roboctrl::device::referee_protocol::state::winner |
该结构体的文档由以下文件生成:
- /home/runner/work/GKD.RoboCtrl/GKD.RoboCtrl/include/device/referee/state.hpp
