载入中...
搜索中...
未找到
通用 PID 控制器实现。 更多...
详细描述
通用 PID 控制器实现。
提供可配置的 PID 基类以及基于线性误差与角度误差的具体别名。 控制循环优先使用显式 dt 的 update(),避免 PID 行为依赖调度频率。
在文件 pid.h 中定义.
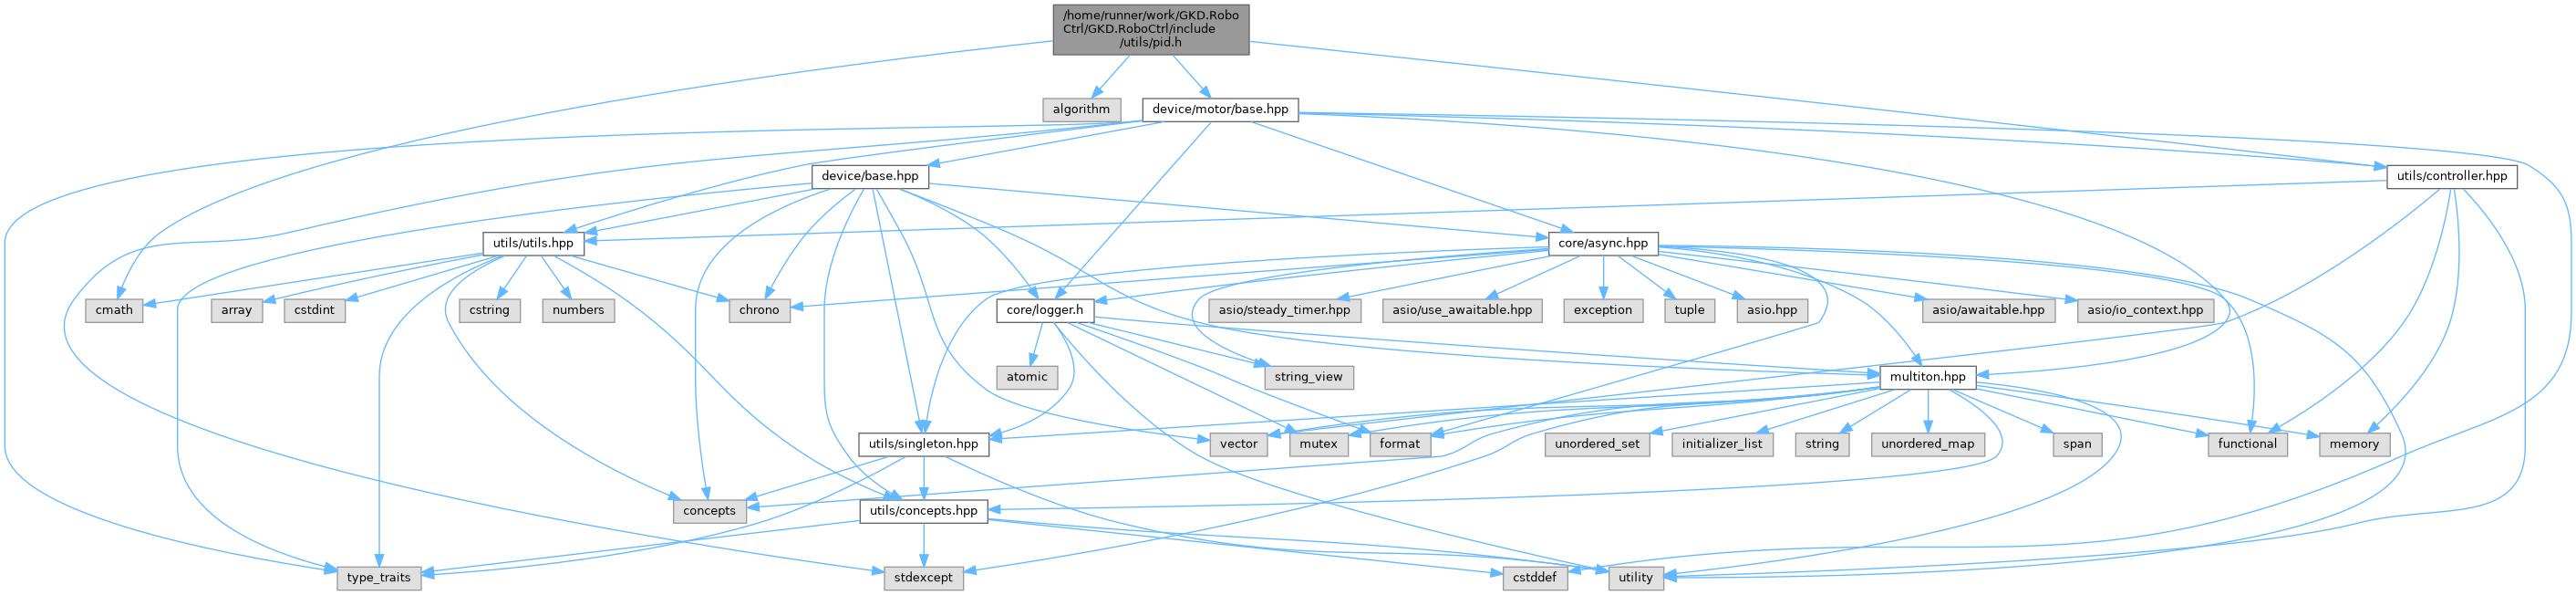
pid.h 的引用(Include)关系图:
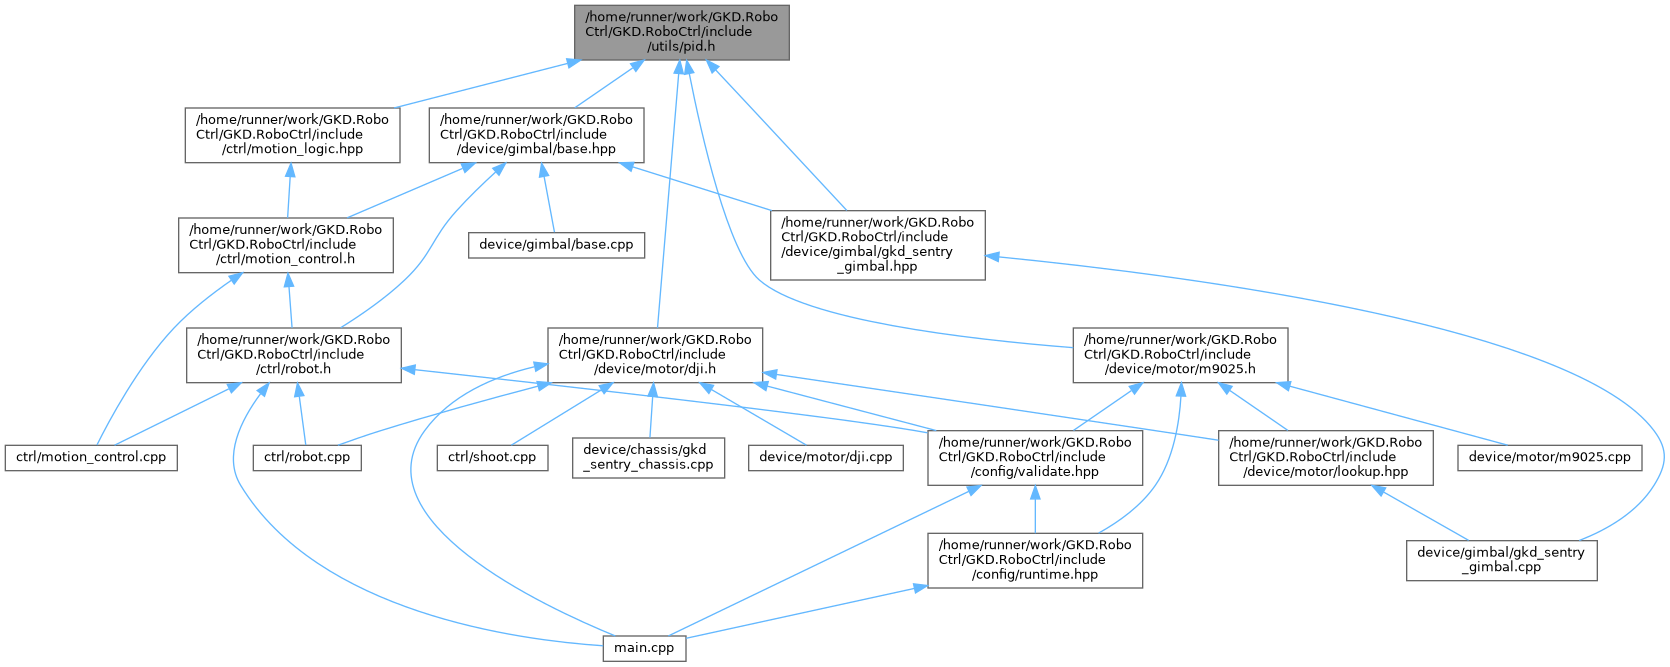
此图展示该文件直接或间接的被哪些文件引用了:
类 | |
| struct | roboctrl::utils::pid_base< T, error_measurer > |
| PID 控制器基础模板。 更多... | |
| struct | roboctrl::utils::pid_base< T, error_measurer >::params_type |
| 统一的参数封装,方便序列化。 更多... | |
命名空间 | |
| namespace | roboctrl::utils |
| 用于存放工具函数的命名空间。 | |
类型定义 | |
| using | roboctrl::utils::linear_pid = pid_base< fp32, details::linear_error > |
| 线性 PID 控制器。 | |
| using | roboctrl::utils::rad_pid = pid_base< fp32, details::rad_error > |
| 角度 PID 控制器。 | |
| template<device::motor motor_type> | |
| using | roboctrl::utils::linear_pid_motor = device::controlled_motor< motor_type, linear_pid > |
| 将线性 PID 附着于特定电机类型的别名。 | |
| template<device::motor motor_type> | |
| using | roboctrl::utils::rad_pid_motor = device::controlled_motor< motor_type, rad_pid > |
| 将角度 PID 附着于特定电机类型的别名。 | |
变量 | |
| constexpr auto | roboctrl::utils::details::linear_error |
| 线性误差计算方式。 | |
| constexpr auto | roboctrl::utils::details::rad_error |
| 角度误差计算方式,自动处理 2π 周期。 | |
变量说明
◆ linear_error
|
constexpr |
初始值:
return target - cur;
}
线性误差计算方式。
