PID 控制器基础模板。 更多...
详细描述
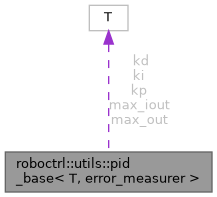
struct roboctrl::utils::pid_base< T, error_measurer >
PID 控制器基础模板。
- 模板参数
-
T 计算类型 error_measurer 误差测度函数
#include <pid.h>
类 | |
| struct | params_type |
| 统一的参数封装,方便序列化。 更多... | |
Public 类型 | |
| using | input_type = T |
| using | state_type = T |
Public 成员函数 | |
| pid_base (const params_type ¶ms) | |
| void | set_target (T target) |
| 设置期望目标。 | |
| T | target () const |
| void | update (T current, T dt) |
| 根据当前值和采样周期更新 PID 输出。 | |
| void | update (T current) |
| void | update (T target, T current, T dt) |
| 同时设置目标并根据当前值更新输出。 | |
| void | clean () |
| 清空积分项、误差缓存与输出。 | |
| T | state () const |
| 获取最新的控制输出。 | |
Public 属性 | |
| T | kp = 0 |
| T | ki = 0 |
| T | kd = 0 |
| T | max_out {} |
| T | max_iout {} |
成员类型定义说明
◆ input_type
| using roboctrl::utils::pid_base< T, error_measurer >::input_type = T |
◆ state_type
| using roboctrl::utils::pid_base< T, error_measurer >::state_type = T |
构造及析构函数说明
◆ pid_base()
|
inline |
成员函数说明
◆ clean()
|
inline |
清空积分项、误差缓存与输出。
被这些函数引用 roboctrl::device::dji_motor::disable(), roboctrl::device::m9025::disable(), roboctrl::device::dji_motor::set(), roboctrl::device::dji_motor::set_angle_speed(), roboctrl::device::m9025::set_angle_speed(), roboctrl::device::dji_motor::set_current(), roboctrl::device::m9025::set_current() , 以及 roboctrl::device::dji_motor::set_enabled().
◆ set_target()
|
inline |
◆ state()
|
inline |
◆ target()
|
inline |
◆ update() [1/3]
|
inline |
Legacy update preserving the historical per-call PID behavior.
引用了 roboctrl::utils::pid_base< T, error_measurer >::update().
被这些函数引用 roboctrl::utils::pid_base< T, error_measurer >::update().
◆ update() [2/3]
|
inline |
根据当前值和采样周期更新 PID 输出。
与传统 RM 风格 PID(error[0]/error[1] 差分)保持兼容:
- 误差缓存顺序:先 old 再 new
- 积分项:I += ki * error * dt
- 微分项:D = kd * (error_curr - error_prev) / dt
- 限幅顺序:先 Iout,再输出
被这些函数引用 roboctrl::device::gkd_sentry_gimbal::update() , 以及 roboctrl::utils::pid_base< T, error_measurer >::update().
◆ update() [3/3]
|
inline |
同时设置目标并根据当前值更新输出。
- 参数
-
target 本次控制的目标值 current 当前反馈值 dt 采样周期,单位为秒
引用了 roboctrl::utils::pid_base< T, error_measurer >::set_target() , 以及 roboctrl::utils::pid_base< T, error_measurer >::update().
类成员变量说明
◆ kd
| T roboctrl::utils::pid_base< T, error_measurer >::kd = 0 |
◆ ki
| T roboctrl::utils::pid_base< T, error_measurer >::ki = 0 |
◆ kp
| T roboctrl::utils::pid_base< T, error_measurer >::kp = 0 |
◆ max_iout
| T roboctrl::utils::pid_base< T, error_measurer >::max_iout {} |
◆ max_out
| T roboctrl::utils::pid_base< T, error_measurer >::max_out {} |
该结构体的文档由以下文件生成:
- /home/runner/work/GKD.RoboCtrl/GKD.RoboCtrl/include/utils/pid.h
