载入中...
搜索中...
未找到
roboctrl::ctrl::power_manager类 参考
详细描述
Control policy only: bounded work on each motion-control tick, no extra thread.
在文件 power_manager.h 第 52 行定义.
#include <power_manager.h>
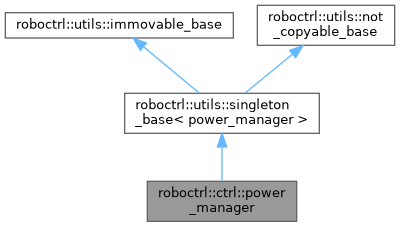
类 roboctrl::ctrl::power_manager 继承关系图:
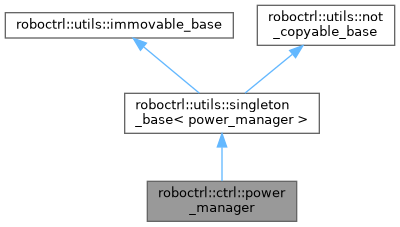
roboctrl::ctrl::power_manager 的协作图:
类 | |
| struct | info_type |
Public 成员函数 | |
| bool | init (const info_type &info) |
| bool | configured () const |
| bool | enabled () const |
| const power_allocation & | status () const |
| power_allocation | allocate (const std::array< power_wheel, 4 > &wheels, const power_feedback &feedback, bool output_allowed, float dt_seconds) |
| void | update (device::chassis_base &chassis, const power_feedback &feedback, bool output_allowed, float dt_seconds) |
| awaitable< void > | update (device::chassis_base &chassis, bool output_allowed, float dt_seconds) |
 Public 成员函数 继承自 roboctrl::utils::singleton_base< power_manager > | |
| singleton_base (const singleton_base &)=delete | |
| singleton_base & | operator= (const singleton_base &)=delete |
| Public 成员函数 继承自 roboctrl::utils::immovable_base | |
| immovable_base (immovable_base &&)=delete | |
| immovable_base & | operator= (immovable_base &&)=delete |
| Public 成员函数 继承自 roboctrl::utils::not_copyable_base | |
| not_copyable_base (const not_copyable_base &)=delete | |
| not_copyable_base & | operator= (const not_copyable_base &)=delete |
静态 Public 成员函数 | |
| static bool | valid_configuration (const info_type &info) |
| 静态 Public 成员函数 继承自 roboctrl::utils::singleton_base< power_manager > | |
| static power_manager & | instance () |
| 获取单例实例 | |
成员函数说明
◆ allocate()
| power_allocation roboctrl::ctrl::power_manager::allocate | ( | const std::array< power_wheel, 4 > & | wheels, |
| const power_feedback & | feedback, | ||
| bool | output_allowed, | ||
| float | dt_seconds | ||
| ) |
Pure numeric entry point; no hardware access or asynchronous work.
在文件 power_manager.cpp 第 152 行定义.
被这些函数引用 update().
◆ configured()
|
inline |
在文件 power_manager.h 第 84 行定义.
◆ enabled()
|
inline |
在文件 power_manager.h 第 85 行定义.
◆ init()
| bool roboctrl::ctrl::power_manager::init | ( | const info_type & | info | ) |
在文件 power_manager.cpp 第 42 行定义.
◆ status()
|
inline |
在文件 power_manager.h 第 86 行定义.
◆ update() [1/2]
| awaitable< void > roboctrl::ctrl::power_manager::update | ( | device::chassis_base & | chassis, |
| bool | output_allowed, | ||
| float | dt_seconds | ||
| ) |
Capture fresh referee/capacitor telemetry in the control layer.
在文件 power_feedback.cpp 第 11 行定义.
引用了 update().
◆ update() [2/2]
| void roboctrl::ctrl::power_manager::update | ( | device::chassis_base & | chassis, |
| const power_feedback & | feedback, | ||
| bool | output_allowed, | ||
| float | dt_seconds | ||
| ) |
Apply the exact allocated absolute caps to the bound wheel actuators.
在文件 power_manager.cpp 第 254 行定义.
引用了 allocate() , 以及 roboctrl::device::chassis_base::wheel_motors().
被这些函数引用 update().
◆ valid_configuration()
|
static |
在文件 power_manager.cpp 第 24 行定义.
该类的文档由以下文件生成:
- /home/runner/work/GKD.RoboCtrl/GKD.RoboCtrl/include/ctrl/power_manager.h
- ctrl/power_feedback.cpp
- ctrl/power_manager.cpp
