载入中...
搜索中...
未找到
roboctrl::ctrl::robot类 参考
详细描述
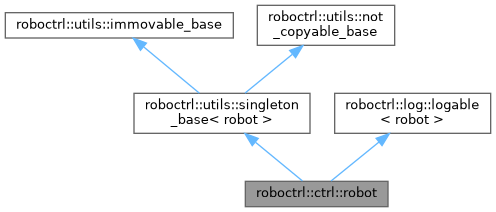
类 roboctrl::ctrl::robot 继承关系图:
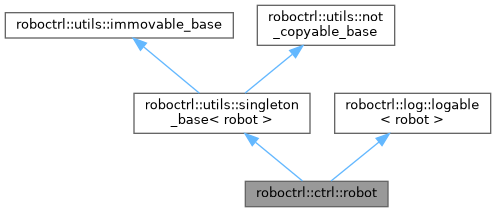
roboctrl::ctrl::robot 的协作图:
类 | |
| struct | info_type |
| 机器人初始化参数及启用的子系统。 更多... | |
Public 成员函数 | |
| bool | init (const info_type &info) |
| 创建具体底盘/云台并初始化控制子系统。 | |
| std::string | desc () const |
| roboctrl::awaitable< void > | task () |
| 运行机器人级状态机任务。 | |
| device::chassis_base * | chassis () noexcept |
| const device::chassis_base * | chassis () const noexcept |
| device::gimbal_base * | gimbal () noexcept |
| const device::gimbal_base * | gimbal () const noexcept |
| device::gimbal_base * | secondary_gimbal () noexcept |
| device::gimbal_base * | large_yaw () noexcept |
| shoot * | secondary_shoot () noexcept |
| bool | gimbals_initialized () const |
| bool | gimbals_online () const |
| robot_state | state () const |
| 获取当前机器人状态。 | |
| void | set_state (robot_state state) |
| 设置当前机器人状态并更新输出使能。 | |
 Public 成员函数 继承自 roboctrl::utils::singleton_base< robot > | |
| singleton_base (const singleton_base &)=delete | |
| singleton_base & | operator= (const singleton_base &)=delete |
| Public 成员函数 继承自 roboctrl::utils::immovable_base | |
| immovable_base (immovable_base &&)=delete | |
| immovable_base & | operator= (immovable_base &&)=delete |
| Public 成员函数 继承自 roboctrl::utils::not_copyable_base | |
| not_copyable_base (const not_copyable_base &)=delete | |
| not_copyable_base & | operator= (const not_copyable_base &)=delete |
额外继承的成员函数 | |
| 静态 Public 成员函数 继承自 roboctrl::utils::singleton_base< robot > | |
| static robot & | instance () |
| 获取单例实例 | |
| Protected 成员函数 继承自 roboctrl::log::logable< robot > | |
| void | log (log_level level, std::format_string< Args... > fmt, Args &&...args) const |
| 输出日志 | |
| void | log_debug (std::format_string< Args... > fmt, Args &&...args) const |
| 输出debug日志 | |
| void | log_info (std::format_string< Args... > fmt, Args &&...args) const |
| 输出info日志 | |
| void | log_warn (std::format_string< Args... > fmt, Args &&...args) const |
| 输出warn日志 | |
| void | log_error (std::format_string< Args... > fmt, Args &&...args) const |
| 输出error日志 | |
成员函数说明
◆ chassis() [1/2]
|
inlinenoexcept |
◆ chassis() [2/2]
|
inlinenoexcept |
◆ desc()
◆ gimbal() [1/2]
|
inlinenoexcept |
◆ gimbal() [2/2]
|
inlinenoexcept |
Return the configured gimbal, or nullptr when the gimbal is disabled.
被这些函数引用 init() , 以及 set_state().
◆ gimbals_initialized()
◆ gimbals_online()
◆ init()
| bool robot::init | ( | const info_type & | info | ) |
创建具体底盘/云台并初始化控制子系统。
引用了 roboctrl::ctrl::robot::info_type::chassis_type, roboctrl::device::gimbal_registry::create(), roboctrl::device::chassis_registry::current(), roboctrl::device::gimbal_registry::current(), gimbal(), roboctrl::ctrl::robot::info_type::gimbal_type, roboctrl::multiton::init(), roboctrl::device::chassis_registry::init(), roboctrl::device::gimbal_registry::init(), roboctrl::log::logable< robot >::log_info(), set_state(), roboctrl::async::spawn() , 以及 task().
◆ large_yaw()
|
inlinenoexcept |
◆ secondary_gimbal()
|
inlinenoexcept |
◆ secondary_shoot()
◆ set_state()
| void robot::set_state | ( | robot_state | state | ) |
◆ state()
|
inline |
◆ task()
| roboctrl::awaitable< void > robot::task | ( | ) |
运行机器人级状态机任务。
引用了 roboctrl::log::logable< robot >::log_warn(), set_state() , 以及 roboctrl::async::wait_for().
被这些函数引用 init().
该类的文档由以下文件生成:
