载入中...
搜索中...
未找到
roboctrl::ctrl::motion_control类 参考
详细描述
在文件 motion_control.h 第 18 行定义.
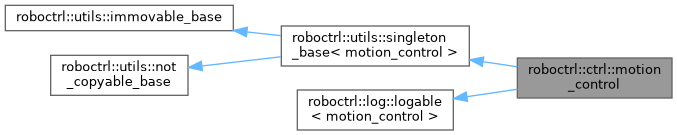
类 roboctrl::ctrl::motion_control 继承关系图:
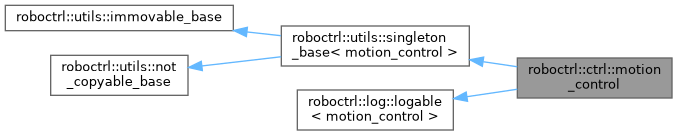
roboctrl::ctrl::motion_control 的协作图:
类 | |
| struct | info_type |
Public 成员函数 | |
| bool | init (const info_type &info) |
| awaitable< void > | task () |
| std::string | desc () const |
 Public 成员函数 继承自 roboctrl::utils::singleton_base< motion_control > | |
| singleton_base (const singleton_base &)=delete | |
| singleton_base & | operator= (const singleton_base &)=delete |
| Public 成员函数 继承自 roboctrl::utils::immovable_base | |
| immovable_base (immovable_base &&)=delete | |
| immovable_base & | operator= (immovable_base &&)=delete |
| Public 成员函数 继承自 roboctrl::utils::not_copyable_base | |
| not_copyable_base (const not_copyable_base &)=delete | |
| not_copyable_base & | operator= (const not_copyable_base &)=delete |
额外继承的成员函数 | |
| 静态 Public 成员函数 继承自 roboctrl::utils::singleton_base< motion_control > | |
| static motion_control & | instance () |
| 获取单例实例 | |
| Protected 成员函数 继承自 roboctrl::log::logable< motion_control > | |
| void | log (log_level level, std::format_string< Args... > fmt, Args &&...args) const |
| 输出日志 | |
| void | log_debug (std::format_string< Args... > fmt, Args &&...args) const |
| 输出debug日志 | |
| void | log_info (std::format_string< Args... > fmt, Args &&...args) const |
| 输出info日志 | |
| void | log_warn (std::format_string< Args... > fmt, Args &&...args) const |
| 输出warn日志 | |
| void | log_error (std::format_string< Args... > fmt, Args &&...args) const |
| 输出error日志 | |
成员函数说明
◆ desc()
|
inline |
在文件 motion_control.h 第 39 行定义.
◆ init()
| bool roboctrl::ctrl::motion_control::init | ( | const info_type & | info | ) |
在文件 motion_control.cpp 第 14 行定义.
◆ task()
| awaitable< void > roboctrl::ctrl::motion_control::task | ( | ) |
在文件 motion_control.cpp 第 195 行定义.
该类的文档由以下文件生成:
- /home/runner/work/GKD.RoboCtrl/GKD.RoboCtrl/include/ctrl/motion_control.h
- ctrl/motion_control.cpp
