载入中...
搜索中...
未找到
运行时配置根对象。 更多...
详细描述
#include <runtime.hpp>
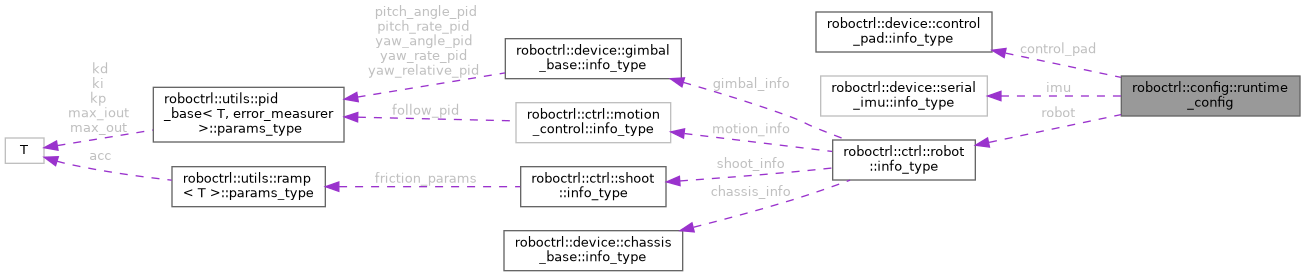
roboctrl::config::runtime_config 的协作图:
Public 属性 | |
| unsigned int | schema_version {1} |
| std::string | profile |
| std::vector< io::can::info_type > | cans |
| std::vector< io::serial::info_type > | serials |
| std::vector< device::dji_motor::info_type > | dji_motors |
| std::vector< device::j6006::info_type > | j6006_motors |
| std::vector< device::m9025::info_type > | m9025_motors |
| std::vector< device::serial_imu::info_type > | additional_imus |
| std::vector< io::udp_server::info_type > | udp_servers |
| std::vector< device::aim_link::info_type > | aim_links |
| std::vector< device::navigation_link::info_type > | navigation_links |
| std::vector< device::remote_logger::info_type > | remote_loggers |
| std::optional< device::referee::info_type > | referee |
| std::optional< device::super_cap::info_type > | super_cap |
| std::optional< ctrl::power_manager::info_type > | power |
| device::control_pad::info_type | control_pad |
| device::serial_imu::info_type | imu |
| ctrl::robot::info_type | robot |
类成员变量说明
◆ additional_imus
| std::vector<device::serial_imu::info_type> roboctrl::config::runtime_config::additional_imus |
在文件 runtime.hpp 第 66 行定义.
◆ aim_links
| std::vector<device::aim_link::info_type> roboctrl::config::runtime_config::aim_links |
在文件 runtime.hpp 第 68 行定义.
◆ cans
| std::vector<io::can::info_type> roboctrl::config::runtime_config::cans |
在文件 runtime.hpp 第 61 行定义.
◆ control_pad
| device::control_pad::info_type roboctrl::config::runtime_config::control_pad |
在文件 runtime.hpp 第 75 行定义.
◆ dji_motors
| std::vector<device::dji_motor::info_type> roboctrl::config::runtime_config::dji_motors |
在文件 runtime.hpp 第 63 行定义.
◆ imu
| device::serial_imu::info_type roboctrl::config::runtime_config::imu |
在文件 runtime.hpp 第 76 行定义.
◆ j6006_motors
| std::vector<device::j6006::info_type> roboctrl::config::runtime_config::j6006_motors |
在文件 runtime.hpp 第 64 行定义.
◆ m9025_motors
| std::vector<device::m9025::info_type> roboctrl::config::runtime_config::m9025_motors |
在文件 runtime.hpp 第 65 行定义.
◆ navigation_links
| std::vector<device::navigation_link::info_type> roboctrl::config::runtime_config::navigation_links |
在文件 runtime.hpp 第 69 行定义.
◆ power
| std::optional<ctrl::power_manager::info_type> roboctrl::config::runtime_config::power |
在文件 runtime.hpp 第 73 行定义.
◆ profile
| std::string roboctrl::config::runtime_config::profile |
在文件 runtime.hpp 第 59 行定义.
◆ referee
| std::optional<device::referee::info_type> roboctrl::config::runtime_config::referee |
在文件 runtime.hpp 第 71 行定义.
◆ remote_loggers
| std::vector<device::remote_logger::info_type> roboctrl::config::runtime_config::remote_loggers |
在文件 runtime.hpp 第 70 行定义.
◆ robot
| ctrl::robot::info_type roboctrl::config::runtime_config::robot |
在文件 runtime.hpp 第 77 行定义.
◆ schema_version
| unsigned int roboctrl::config::runtime_config::schema_version {1} |
在文件 runtime.hpp 第 58 行定义.
◆ serials
| std::vector<io::serial::info_type> roboctrl::config::runtime_config::serials |
在文件 runtime.hpp 第 62 行定义.
◆ super_cap
| std::optional<device::super_cap::info_type> roboctrl::config::runtime_config::super_cap |
在文件 runtime.hpp 第 72 行定义.
◆ udp_servers
| std::vector<io::udp_server::info_type> roboctrl::config::runtime_config::udp_servers |
在文件 runtime.hpp 第 67 行定义.
该结构体的文档由以下文件生成:
- /home/runner/work/GKD.RoboCtrl/GKD.RoboCtrl/include/config/runtime.hpp
